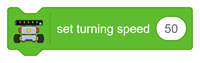
This block sets the speed at which the robot rotates while performing a junction turn.
How It Works
The configured speed determines how quickly the robot pivots towards the selected line.
- Higher values produce faster turns.
- Lower values produce slower turns.
A speed that is too low may not generate enough torque to rotate the robot, while an excessively high speed can cause it to overshoot the intended line.
Python Function – Quarky and Quarky Intellio:
lf5ir.setturningspeed(50)
Example: Set the turning speed to 50 to configure the robot’s turning movement.
The appropriate value depends on the motor performance, wheel arrangement, and track conditions.