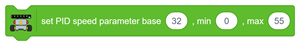
This block configures the motor speeds used during PID-based line following.
| Parameter | Description |
| Base | Sets the normal motor speed when the line is centred. |
| Min | Sets the minimum motor speed allowed during PID correction. |
| Max | Sets the maximum motor speed allowed during PID correction. |
How It Works
The PID controller calculates a steering correction based on the line-position error.
It then increases one motor’s speed and decreases the other motor’s speed relative to the configured base value.
The minimum and maximum values limit the resulting motor speeds to the selected range.
Python Function – Quarky and Quarky Intellio:
lf5ir.setpidspeedparameter5ir(32, 0, 55)
Example: Set the base speed to 32, minimum speed to 0, and maximum speed to 55 to configure the PID motor speed limits.