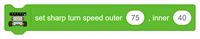
This block sets the motor speeds used when the robot needs to make a sharp directional correction.
How It Works
When the line is detected only by the leftmost or rightmost sensor, the robot applies a stronger correction to return towards the path.
| Parameter | Description |
| Outer | Speed of the wheel on the outside of the turn. |
| Inner | Speed of the wheel on the inside of the turn. |
The outer wheel runs faster than the inner wheel, helping the robot turn sharply towards the detected line.
Python Function – Quarky and Quarky Intellio:
lf5ir.setSharpTurnParameter5IR(75, 40)
Example: Set the outer speed to 75 and the inner speed to 40 to configure the sharp-turn correction.