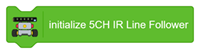
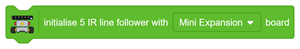
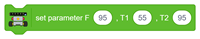
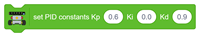
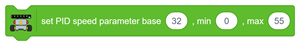
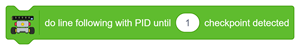
This block configures the forward speed and correction speeds used during standard line following.
| Parameter | Description |
| F | Sets the forward speed when the line is centred. |
| T1 | Sets the lower motor speed used for gentle steering corrections. |
| T2 | Sets the higher motor speed used for gentle steering corrections. |
How It Works
When the line is centred beneath the robot, both motors run at the configured forward speed.
If the line moves slightly towards one side, the robot changes the relative speeds of its wheels to correct its direction.
The wheel on the side towards which the line has shifted runs slower, while the opposite wheel runs faster, helping the robot steer back towards the line.
Python Function – Quarky and Quarky Intellio:
lf5ir.setlinefollowerparameter5ir(95, 55, 95)
Example: Set F to 95, T1 to 55, and T2 to 95 to configure the standard line-following speeds.