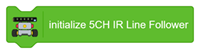
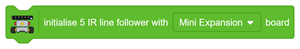
This block initialises the sensor array using the selected Mini Expansion Board or Expansion Board connected to Quarky Intellio.
The dropdown provides two options:
| Board | Description |
| Mini Expansion | Uses the Mini Expansion Board’s I2C and motor-control interfaces. |
| Expansion | Uses the Expansion Board’s I2C and motor-control interfaces. |
The block reuses the selected expansion board’s existing I2C interface and motor driver for sensor communication and robot movement.
Python Function – Quarky Intellio (Mini Expansion):
lf5ir = LineFollower5IR(
i2c=mini.i2c,
motor_driver=mini
)
Python Function – Quarky Intellio (Expansion Board):
lf5ir = LineFollower5IR(
i2c=intellioexpansion.i2c,
motor_driver=intellioexpansion
)
These Python examples assume that the selected expansion-board object has already been initialised.
Note: Always select the board that matches your physical connection before using other blocks from the extension.