
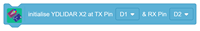

Initialises the YDLIDAR X2 laser scanner through UART communication using the specified RX pin. Connect the LiDAR TX pin to Quarky’s RX pin; a Quarky TX connection is not required for receiving scan data. Connect the LiDAR M_CTRL pin to 3.3 V to keep the scanning motor running continuously.
Allow approximately three seconds for the motor to spin up before reading distance data. This block is available in Upload Mode only.