


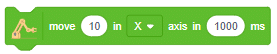
This block is used to move the robotic arm from its current position to a specific X, Y, and Z coordinate position over a specified period of time. This block first moves in the X axis, then the Y axis, and lastly Z axis to reach the desired point.
Table of Contents
move along the X () Y () Z () axis one by one in () ms
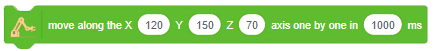
- PictoBlox Extension: Quarky Robotic Arm
- Type: Stack Block
- Mode: Stage Mode, Upload Mode
Description
Example
There are no examples documented for this article.
- Scratch Based Default Extensions
- Artificial Intelligence
- Innovative Extensions
- Machine Learning Environment
- Quarky
- Quarky Intellio I2C Communication
- Quarky Advance Sensors Extension
- Quarky Connect
- Display (Quarky)
- Quarky (Main)
- Robot (Quarky)
- Sensors (Quarky)
- Speaker (Quarky)
- Quarky Ultimate Robots
- Quarky Expansion Board
- Mars Rover
- Humanoid (Quarky)
- Quadruped (Quarky)
- IoT House (Quarky)
- Quarky Mecanum
- Quarky Robotic Arm
- Dabble
- Quarky Advance Line Following