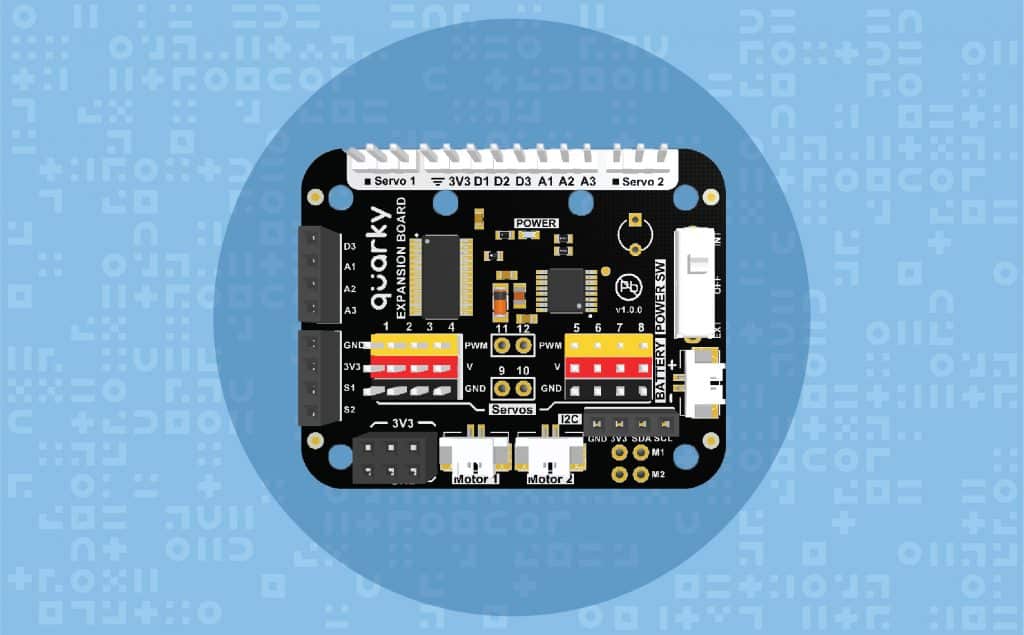
The function moves all the servo motors connected to the Quarky Expansion board servo ports 1 through 8.
moveall()
Function Definition: moveall(angle 1 = 90, angle 2 = 90, angle 3 = 90, angle 4 = 90, angle 5 = 90, angle 6 = 90, angle 7 = 90, angle 8 = 90, time = 1000)
- Python Library: Quarky Expansion Board
- Library Import: quarkyexpansion = Expansion()
- Mode: Stage Mode, Upload Mode
Parameters
| Name | Type | Description | Expected Values | Default Value |
|---|---|---|---|---|
| angle 1 | int | Angle of the servo connected to port 1. | 0 to 180 | 90 |
| angle 2 | int | Angle of the servo connected to port 2. | 0 to 180 | 90 |
| angle 3 | int | Angle of the servo connected to port 3. | 0 to 180 | 90 |
| angle 4 | int | Angle of the servo connected to port 4. | 0 to 180 | 90 |
| angle 5 | int | Angle of the servo connected to port 5. | 0 to 180 | 90 |
| angle 6 | int | Angle of the servo connected to port 6. | 0 to 180 | 90 |
| angle 7 | int | Angle of the servo connected to port 7. | 0 to 180 | 90 |
| angle 8 | int | Angle of the servo connected to port 8. | 0 to 180 | 90 |
| time | int | Time in miliseconds for the movement. | 0 to 10000 | 1000 |
Description
Example
There are no examples documented for this article.
- Scratch Based Default Extensions
- Artificial Intelligence
- Innovative Extensions
- Machine Learning Environment
- Quarky
- Quarky Intellio I2C Communication
- Quarky Advance Sensors Extension
- Quarky Connect
- Display (Quarky)
- Quarky (Main)
- Robot (Quarky)
- Sensors (Quarky)
- Speaker (Quarky)
- Quarky Ultimate Robots
- Quarky Expansion Board
- Mars Rover
- Humanoid (Quarky)
- Quadruped (Quarky)
- IoT House (Quarky)
- Quarky Mecanum
- Quarky Robotic Arm
- Dabble
- Quarky Advance Line Following